Introduction
Pedro brings diverse technical experience across multiple domains, with a strong foundation in engineering principles and a proven track record in full-stack development.
Following graduation, Pedro applied his technical skills in production and manufacturing environments before transitioning to software development. He subsequently specialized in building both backend and frontend components for user-facing interfaces, progressing into full-stack development for desktop applications with 2D and 3D interface capabilities.
He’s quite flexible and adapts quickly to any tool that get’s the job well done. He’s stoic in his way of working, and is not afraid of the effort behind any task, as long as he believes the goal. While working, he likes to keep in mind how the final product is to be accepted and adopted by the final users.
TLDR
As a programmer, Pedro has at least the following years of professional experience:
C++
5/8
C
2/8
Python
1/8
Career
Mar. 2026– Current
Career Break / Sabbatical
Tools: PyTorch · QML· Blender
- Planned time off to pivot, update and strengthen technical skills, with a focus on better alignment with current industry needs.
Oct. 2025– Mar. 2026
Critical TechWorks
Tools: Python · CI/CD workflows
- Developed Python plug-ins for the NVIDIA Omniverse 3D Engine to support the simulation of BMW factory digital twins.
Sep. 2022– Sep. 2025
Toon Boom Animation
Tools: C++ · Qt · Python · JavaScript · Linux
- As a member of the R&D team for Harmony and Storyboard, contributed across multiple application layers: fixing bugs, optimizing algorithms, adding UI features, improving Python/JavaScript function bindings, and contributing to the integration of Maya and Blender as external rendering tools.
Jul. 2021– Aug. 2022
PeekMed®
Tools: C++ · Qt · OpenCV · VTK/ITK
- Led development of C++/Qt features for medical 2D/3D visualization and surgical planning using DICOM, OpenCV, VTK, and ITK. Developed UI modules for virtual bone cuts and implant placement, and improved PACS server/client integration.
Feb. 2019– Jun. 2021
Bosch Car Multimedia
Tools: C++ · Qt · ROS · Linux · C · Matlab
- Co-developed an internal C++/Qt 3D visualization tool for visualizing LiDAR point-cloud data from test vehicles.
- Developed C embedded software for a new generation of Steering Angle Sensors using CAN/SENT and AUTOSAR principles, following ISO 26262 practices.
- As an ISTQB-certified QA tester, developed automated C-based system tests used in the manufacturing of Steering Angle Sensors for multiple vehicle brands.
Oct. 2017– Oct. 2018
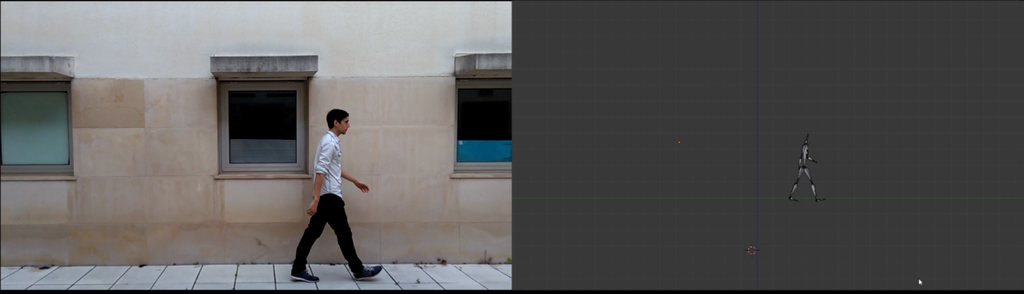
Glymt
Tools: Matlab · C/C++ · OpenCV · OpenGL
- Developed an experimental 3D motion-capture application, using computer-vision algorithms for human-body motion tracking, with the objective of extracting 3D animated rigs from 2D video.
Education
Sep. 2012– Sep. 2017
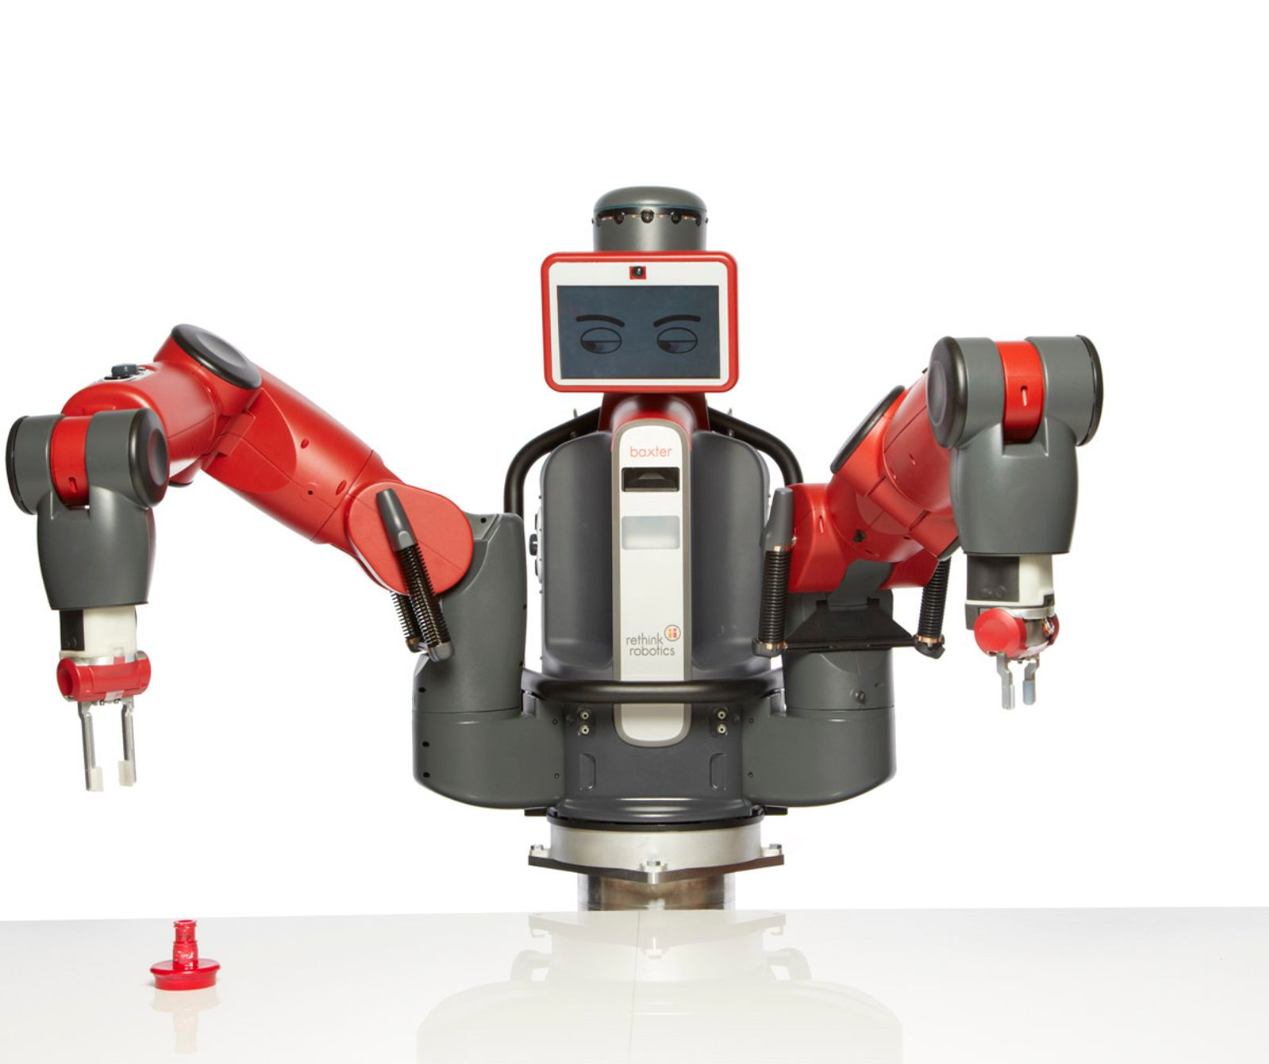
University of Coimbra: M.Sc. in Electronic and Computer Engineering,
- M.Sc. in Electronic and Computer Engineering, specialization in Computer Vision and Robotics.
- Thesis: Autonomous pick-and-place with a Baxter collaborative robot using adaptive inverse kinematics and multimodal sensor fusion from 3D vision and haptic feedback.